Overview
Modern manufacturing faces a turning point: how do we shift from mass production to truly customized, agile factories? While robots have long enabled scale, their use today is constrained by inflexible systems that demand long calibration and static setups.
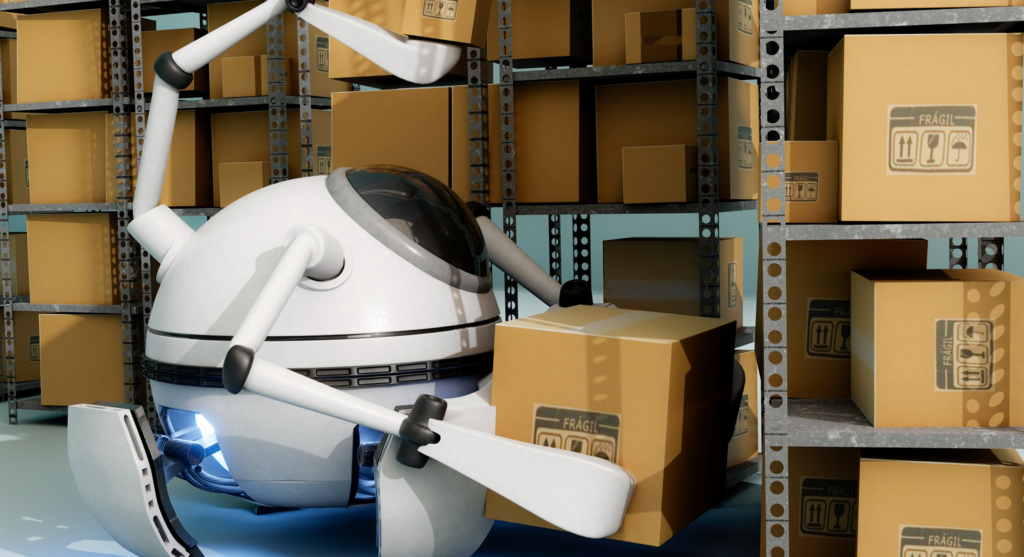
This project envisions the next generation of manufacturing systems: adaptive, mobile robot teams that coordinate to carry out complex assembly tasks autonomously. We develop algorithms and systems allowing multi-robot collaboration in tasks demanding multiple operations, variable precision, and robust recovery.
Key Challenges & Innovations
- Multi-scale perception and manipulation
Assembly requires both coarse operations (e.g. moving large parts) and fine tasks (aligning holes, inserting fasteners) — each demands different sensing and precision regimes.We adopt a hierarchical planning framework, where perception resolution adapts to the demands of the ongoing manipulation. - Coordination among heterogeneous robots
Different robots may carry different tools or sensors. Effective collaboration requires dynamic task assignment, communication, and synchronized motion. - Failure detection & recovery
Long, multi-step assembly chains increase the probability of errors. The system monitors whether current sensing or control fidelity is insufficient and can revert to coarser strategies or re-localize as needed.
Technical Approach
- Hierarchical sensor orchestration
We model each sensor by its scope (field of view) and accuracy. The system plans sequences of sensor usage (from coarse to fine) that match the demands of manipulation tasks. - Collaborative transport & assembly
Robot teams coordinate to carry large structural components that single robots cannot move alone. Once parts are placed, finer manipulation occurs—aligning, fastening, and joint insertion—in collaboration. - Adaptive re-localization and resiliency
If tracking fails at a fine scale, robots can back off to broader sensors to regain context, then resume finer operations with updated estimates. This ensures robustness over changing environments. - Experimental validation
The system was implemented on four KUKA youBot robots. In one demonstration, the robotic team carried out 80 fastener insertion tasks successfully, showing the viability of the method in realistic assembly settings.
Impact & Future Directions
- Towards flexible, reconfigurable factories
This work points toward manufacturing environments that can reconfigure for different products without rigid infrastructure and long downtime. - Scalability and heterogeneity
Future work includes scaling to larger numbers of robots, more varied toolsets, and integration with human–robot collaboration paradigms. - Transfer to industry
While initial demonstrations are in lab settings, the framework is designed to support technology transfer to real factory environments with adaptations to dynamics, uncertainties, and evolving product types.
Collaborators & Acknowledgments
Co-authors and contributors: Mehmet Dogar, Ross Knepper, Andrew Spielberg, Changhyun Choi, Henrik Christensen, and others.
Supported by MIT CSAIL and associated robotics labs.