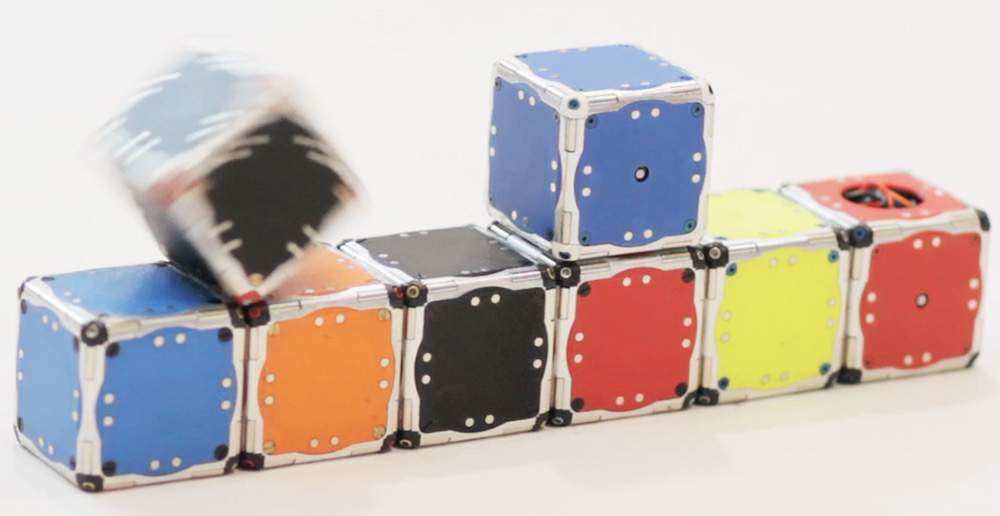
We are developing self-organizing systems of robots. Self-reconfiguring robots have the ability to modify their geometry without human intervention. They take on the body shape most suited for the task at hand.
The idea is to make a module or voxel that can move to sit on another voxel, then another, so that it can build different shapes. And eventually, the modules can turn themselves into a support beam, a tool, a robot with a different number of limbs, etc. We are developing new designs for self-reconfiguring robots and new planning and control algorithms to control the reconfiguration of the robot and its motion.
We have developed a several approaches to self-reconfiguring robots including The Molecule Robot, the Crystal Robot, the Shady Robot, the Pebbles, and M-blocks.